

ROS 2 Robotic Arm Mastery: MoveIt2, Gazebo & VLA Models
Published 8/2026
MP4 | Video: h264, 1920×1080 | Audio: AAC, 44.1 KHz, 2 Ch
Learn to build, simulate and control a robotic manipulator from the ground up, using ROS 2 and
MoveIt2.
Most robotics courses stop at mobile robots. This one goes where the jobs are: manipulation.
You will build a complete robot arm from an empty file, describe it in URDF and Xacro, give it
physics and controllers, plan collision-free motions with MoveIt2, attach a gripper, and
finish with a full pick-and-place system you can put in a portfolio.
Everything runs in simulation. No robot hardware required.
actually matters for manipulation. Transforms and kinematics are derived on screen, not
asserted on a slide. Then you build: URDF and Xacro, meshes and collision geometry,
ros2_control, and spawning your arm into Gazebo with real physics underneath it.
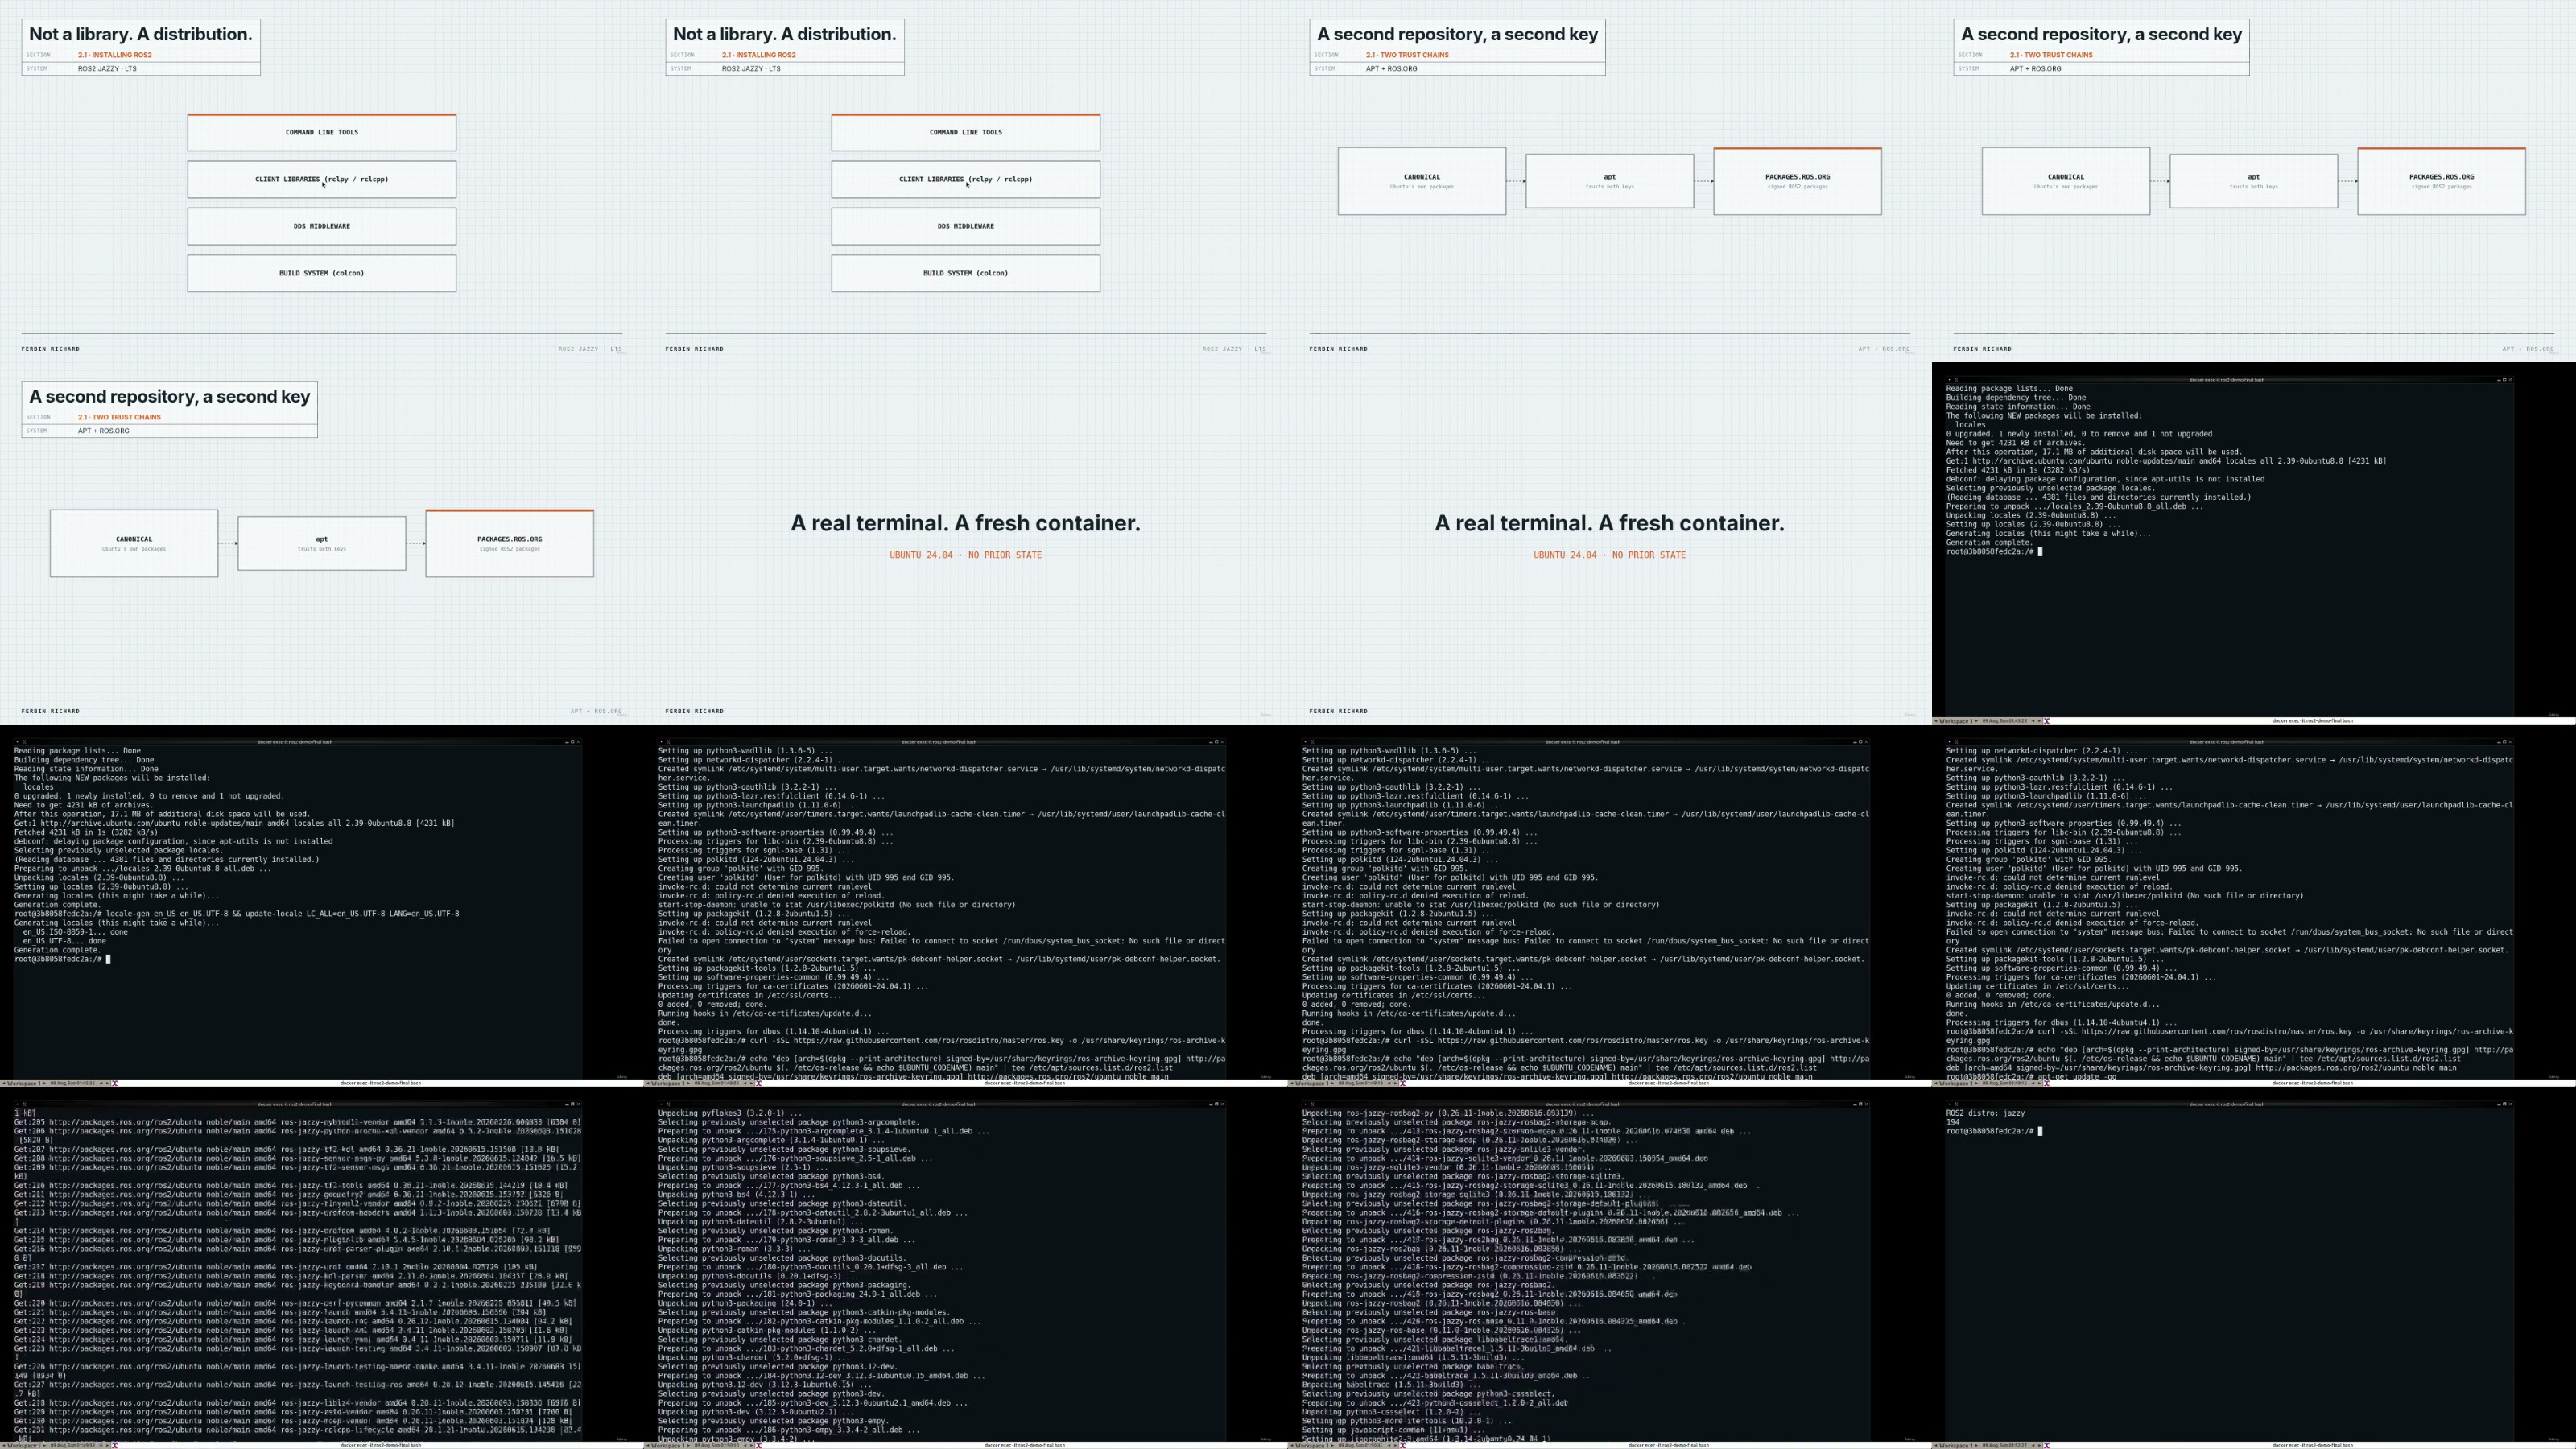
From there you go deep on MoveIt2 across a full section: the Setup Assistant, OMPL planners,
failures deliberately and fix them on camera, because reading an error message is the skill
that actually transfers.
policies, covering where learned methods genuinely help, where classical planning still wins,
and how the two fit together. Very few manipulator courses touch this at all.
You will also cover grippers and grasp mechanics, force closure, attach and detach so the
planner treats a grasped object correctly, camera and depth perception feeding into
manipulation, reinforcement learning foundations, and an honest look at the sim-to-real gap.
By the end you will have built a working manipulation stack end to end, and understand every
layer well enough to debug it when it breaks.

RapidGator
https://www.keeplinks.org/p27/6a96b829953f4
DDownload
https://www.keeplinks.org/p27/6a96b87637888
NitroFlare
https://www.keeplinks.org/p27/6a96b90bb3af0